Adapt to the object.
The linked two-finger mechanism conforms to the object. Force and position control support different gripping tasks, with grip-state feedback and object-drop detection.
90 N rated gripping force. 95 mm total stroke. Adaptive gripping in a compact 0.8 kg end effector.
Configuration on request.
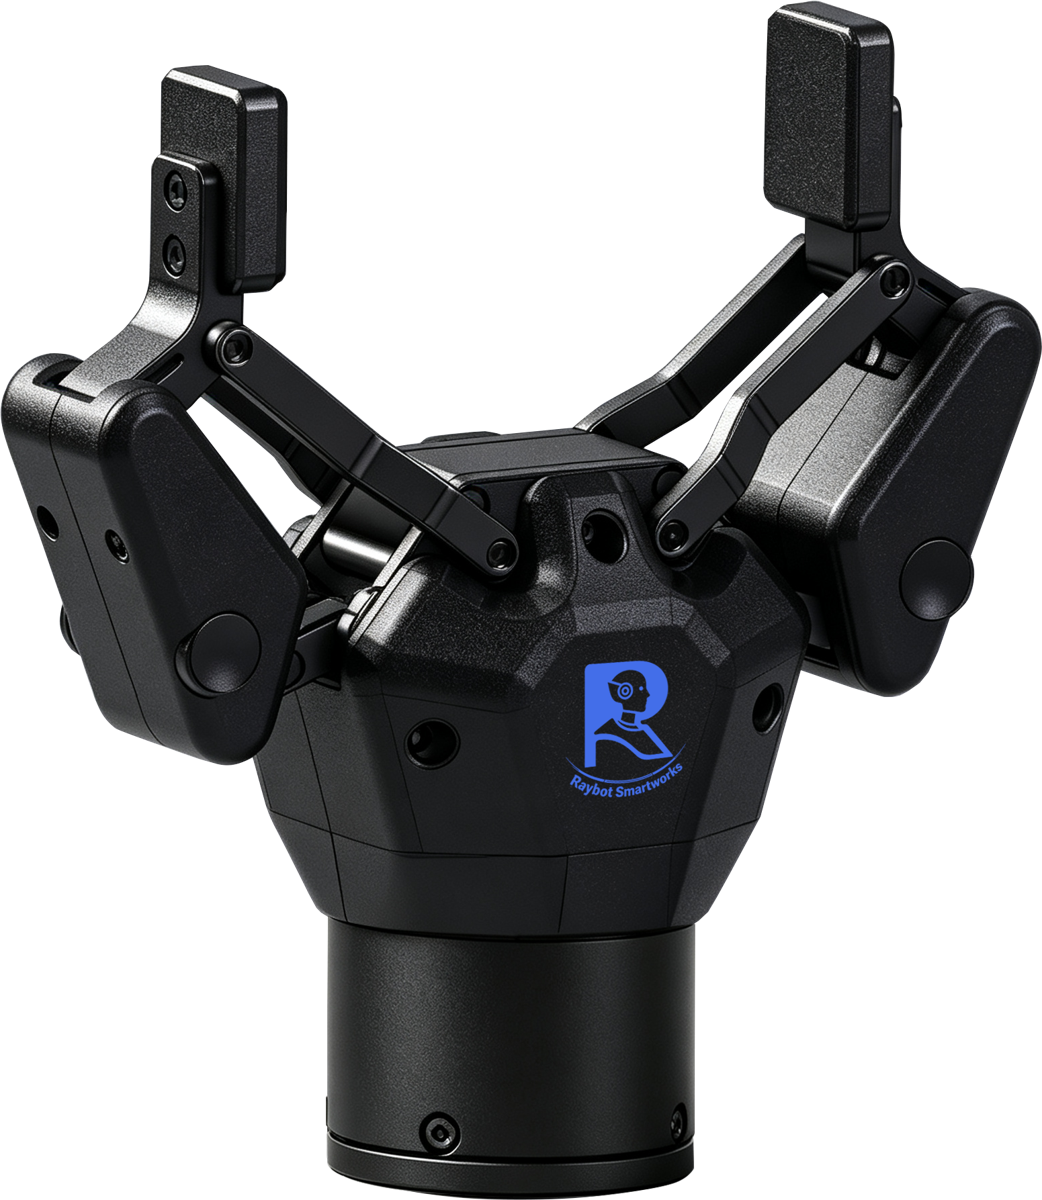
The linked two-finger mechanism conforms to the object. Force and position control support different gripping tasks, with grip-state feedback and object-drop detection.
The planetary gear, screw nut and linkage transmission fits a compact 0.8 kg body. CAN and EtherCAT manuals cover commands, feedback and commissioning.
Rated gripping force is measured at a gripping stroke of 50 mm.
120 N rated gripping force. 105 mm total stroke. Adaptive two-finger gripping with CAN and EtherCAT.
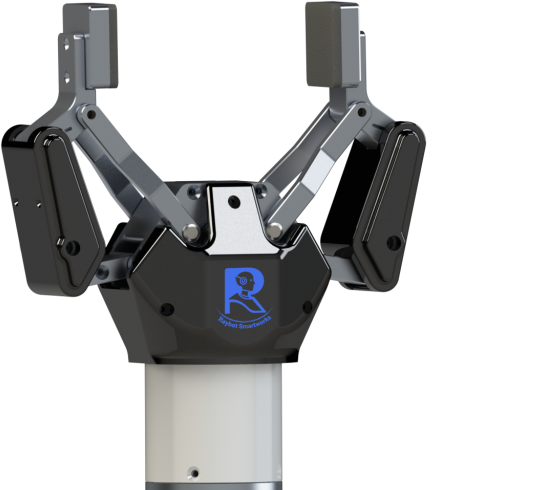 View product
Seven axes. 850 mm reach. A 10 kg payload for embodied intelligence and precision automation.
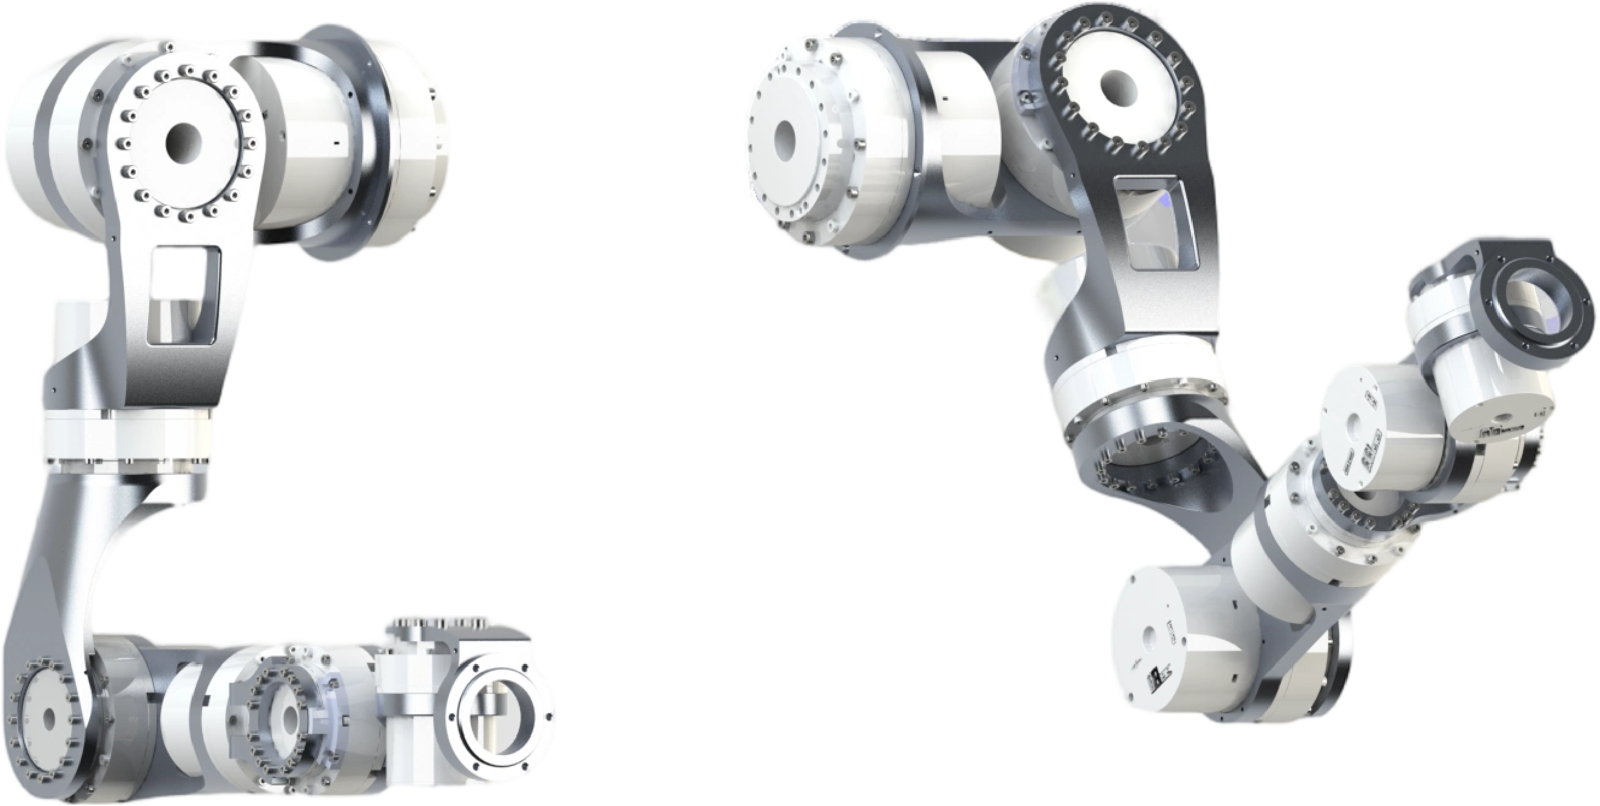 View product
The confirmed total stroke is 95 mm. The overall dimensions are 169.8 × 172.67 × 62.5 mm.
Rated gripping force is 90 N, measured at a gripping stroke of 50 mm. Peak gripping force is 120 N.
The operating voltage is 24–48 V. CAN and EtherCAT communication are supported; use the matching operation manual for your interface.
Yes. Download the outline drawing from this page or the resource center.
Choose the model and quantity on the inquiry page. Raybot will confirm the configuration, pricing and lead time for your application.
Email tangxc@myactuator.com or call +86 17775378663 with your model, firmware version and integration requirements.