Move with precision
Six or seven axes. Choose the reach and payload for your application.
Connect. Control. Create.
Six or seven axes. Choose the reach and payload for your application.
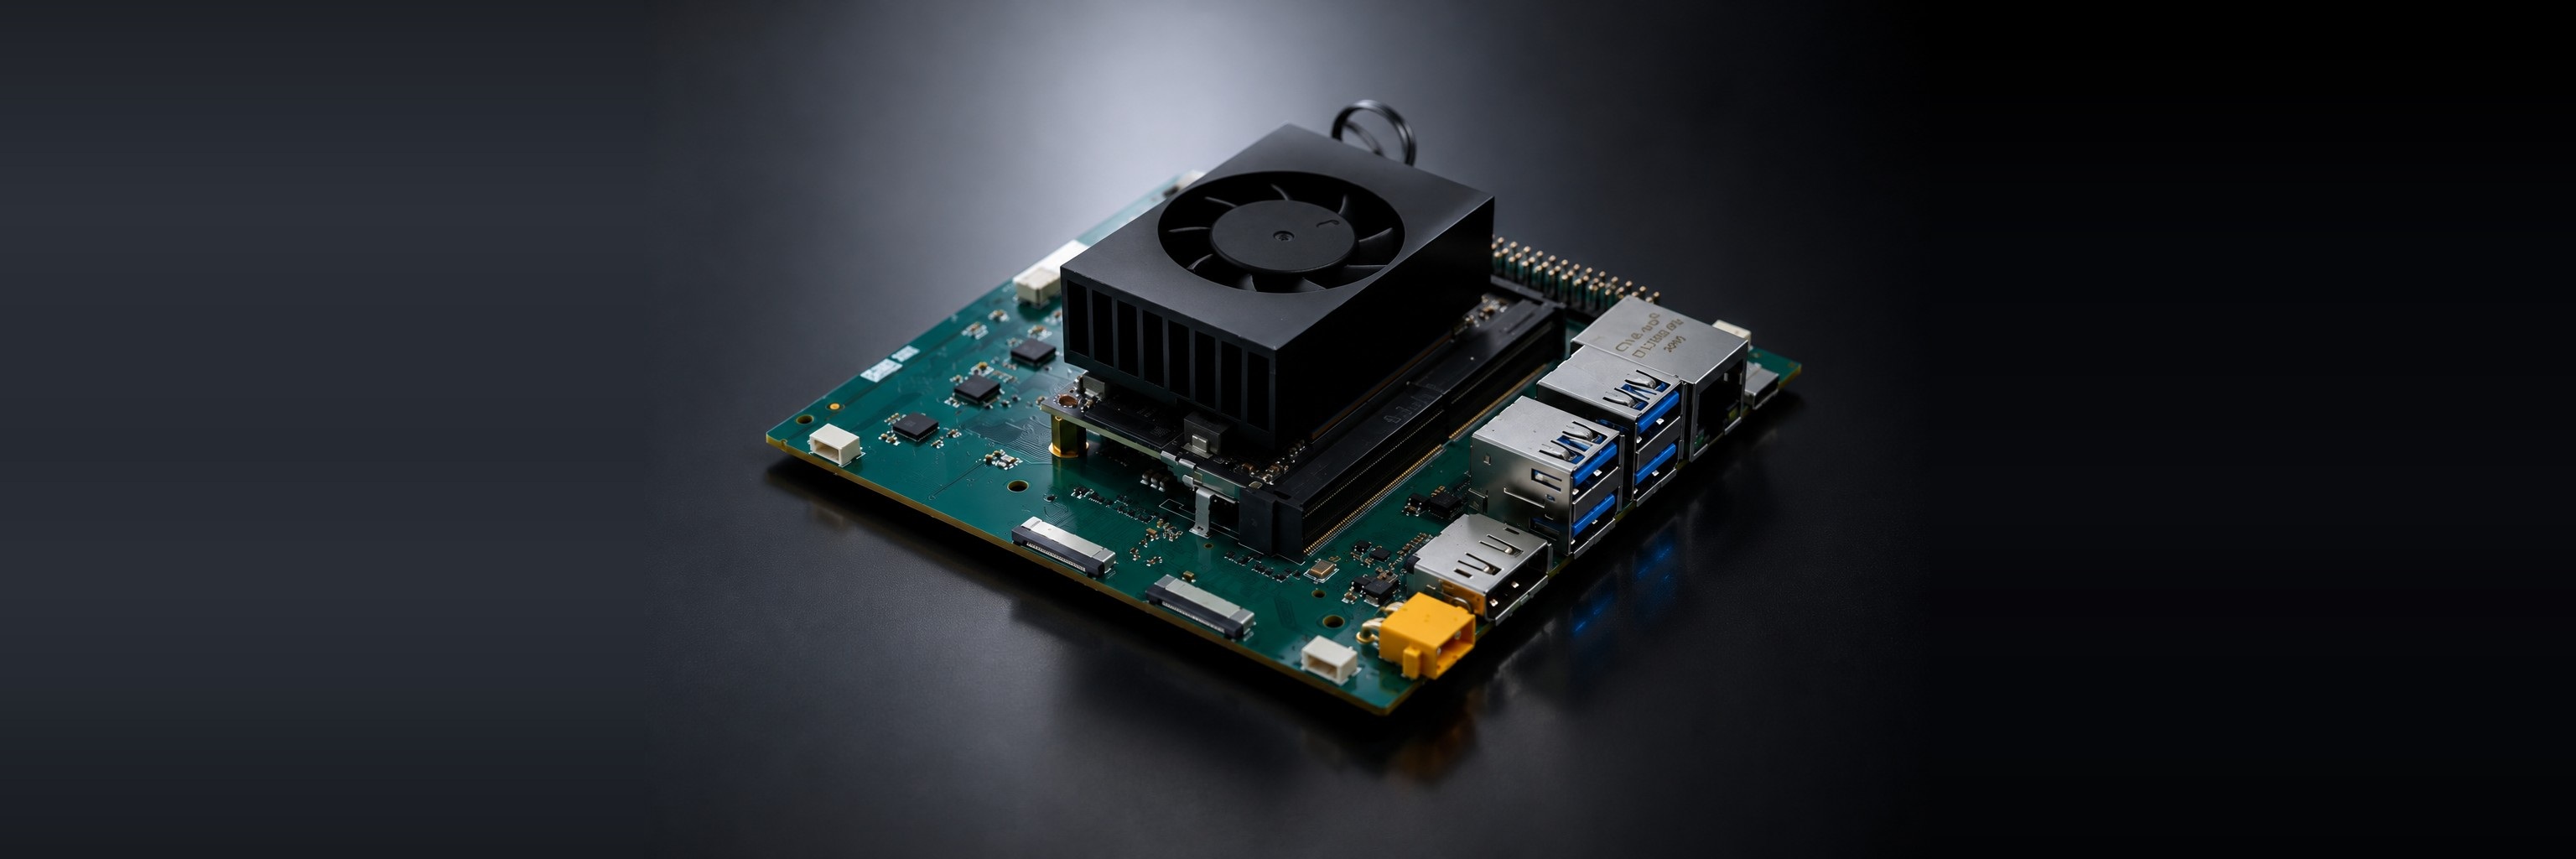
EtherCAT motion control, with an option for Jetson Orin NX SUPER compute.
90 N and 120 N rated gripping force. CAN and EtherCAT integration.
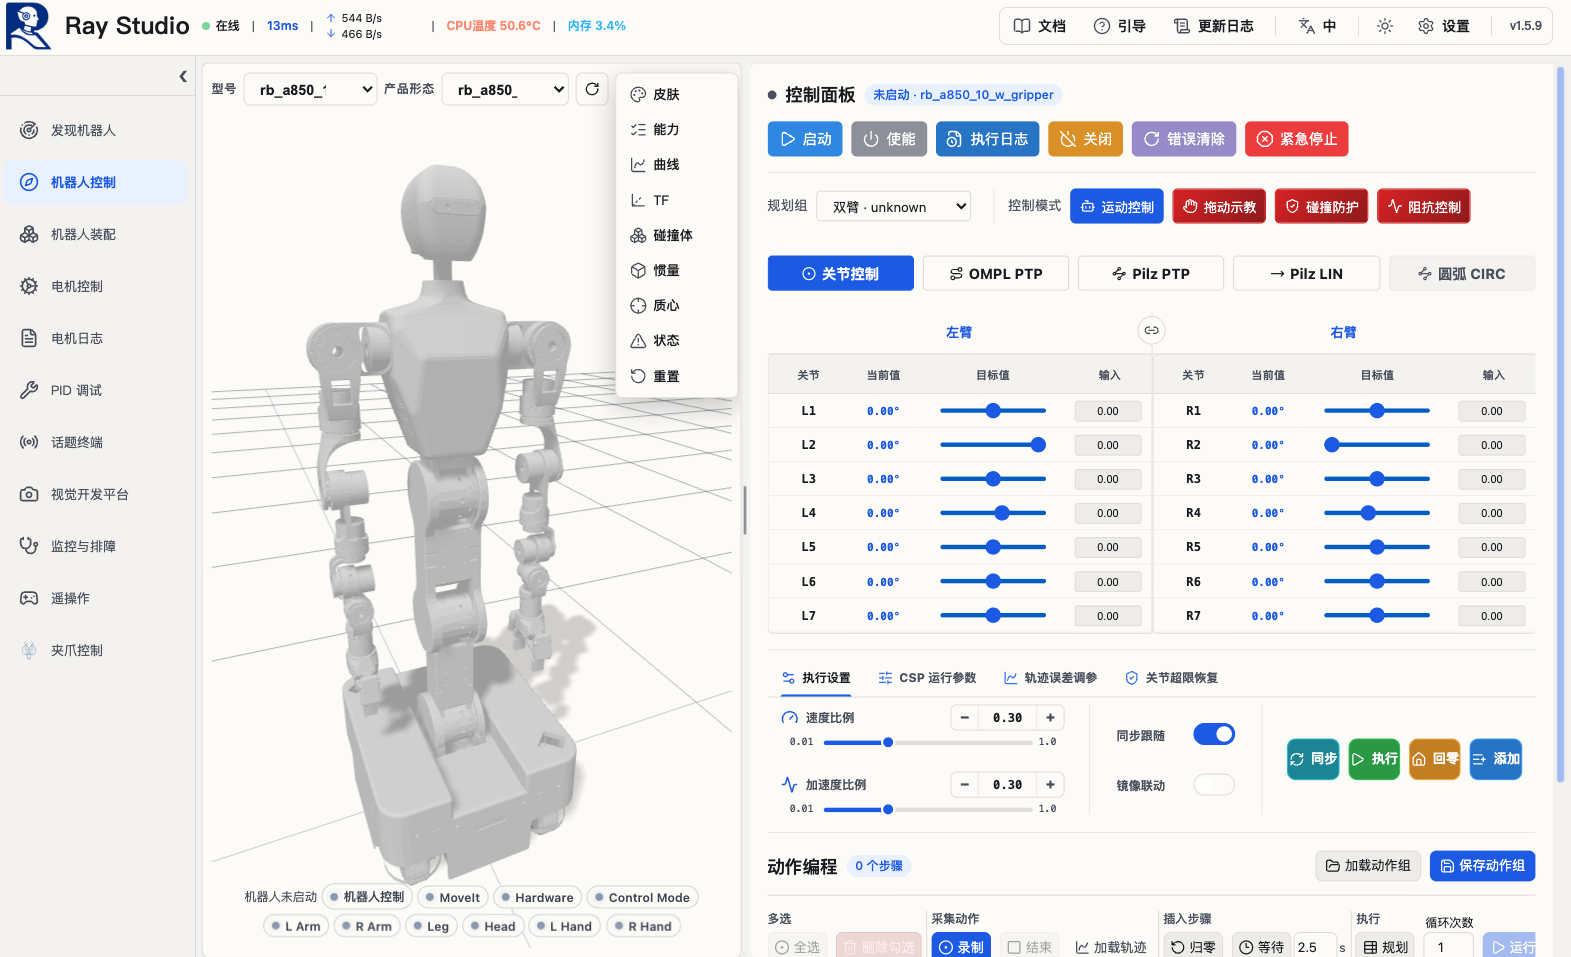
Browser control, zero-force teaching, motor PID tuning and real-time visualization. RayStudio connects our robot hardware with the tools you use to develop intelligent applications.
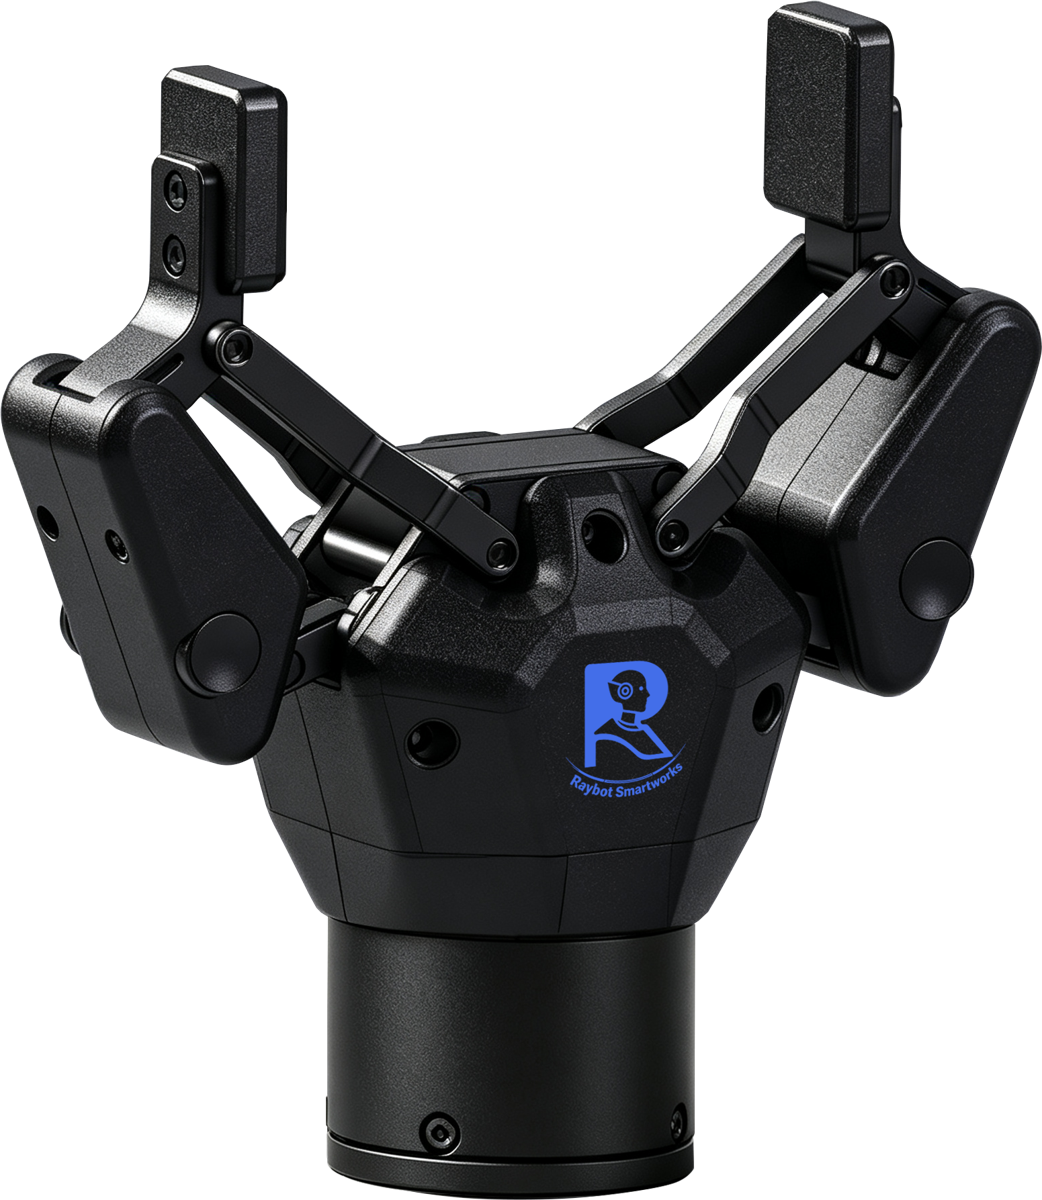
90 N rated gripping force. 95 mm total stroke. Adaptive gripping in a compact 0.8 kg end effector.
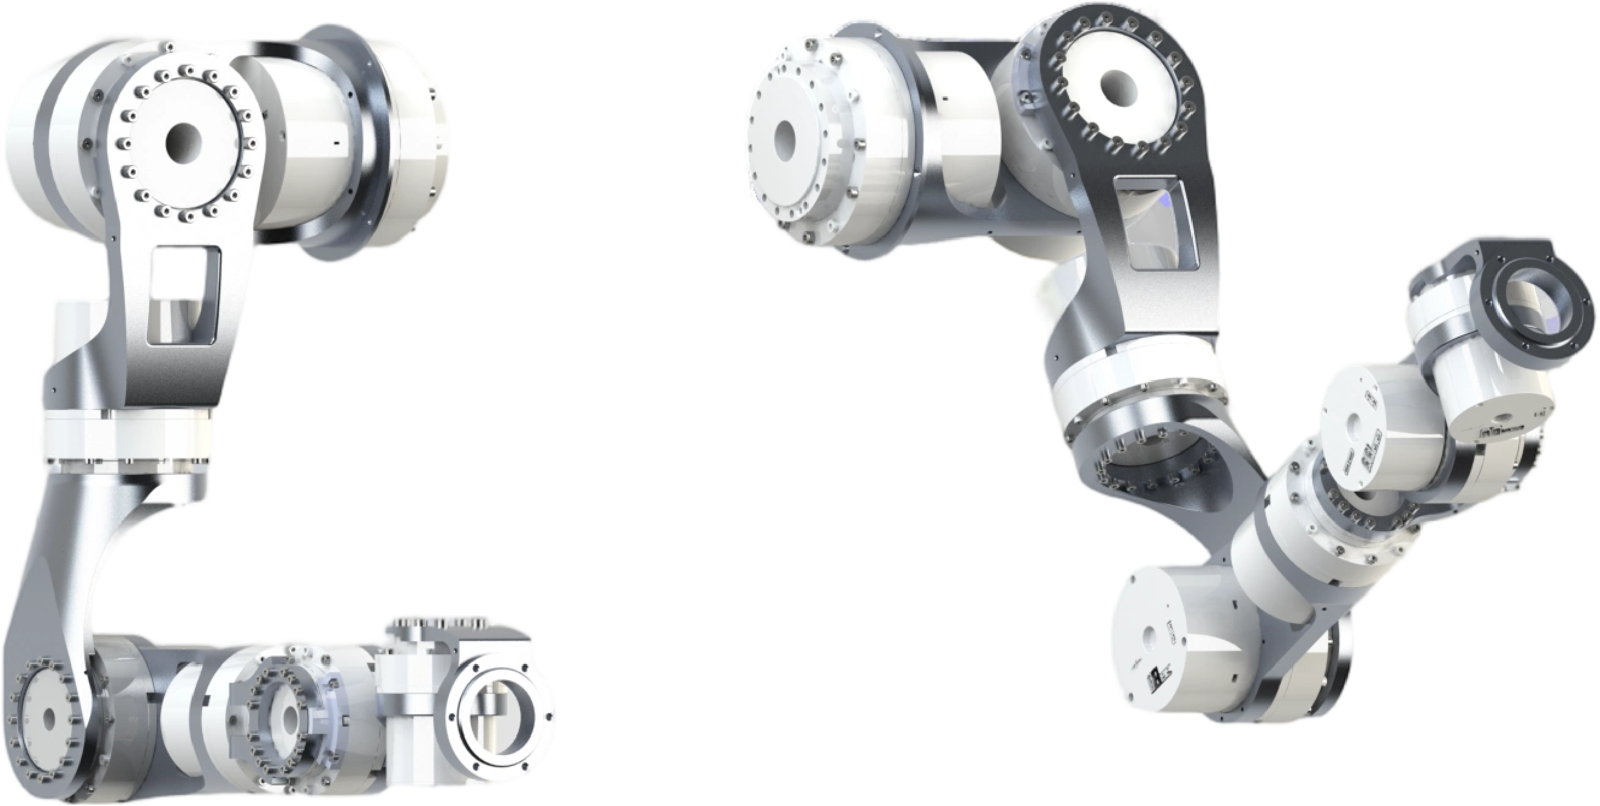
Seven axes. 850 mm reach. A 10 kg payload for embodied intelligence and precision automation.
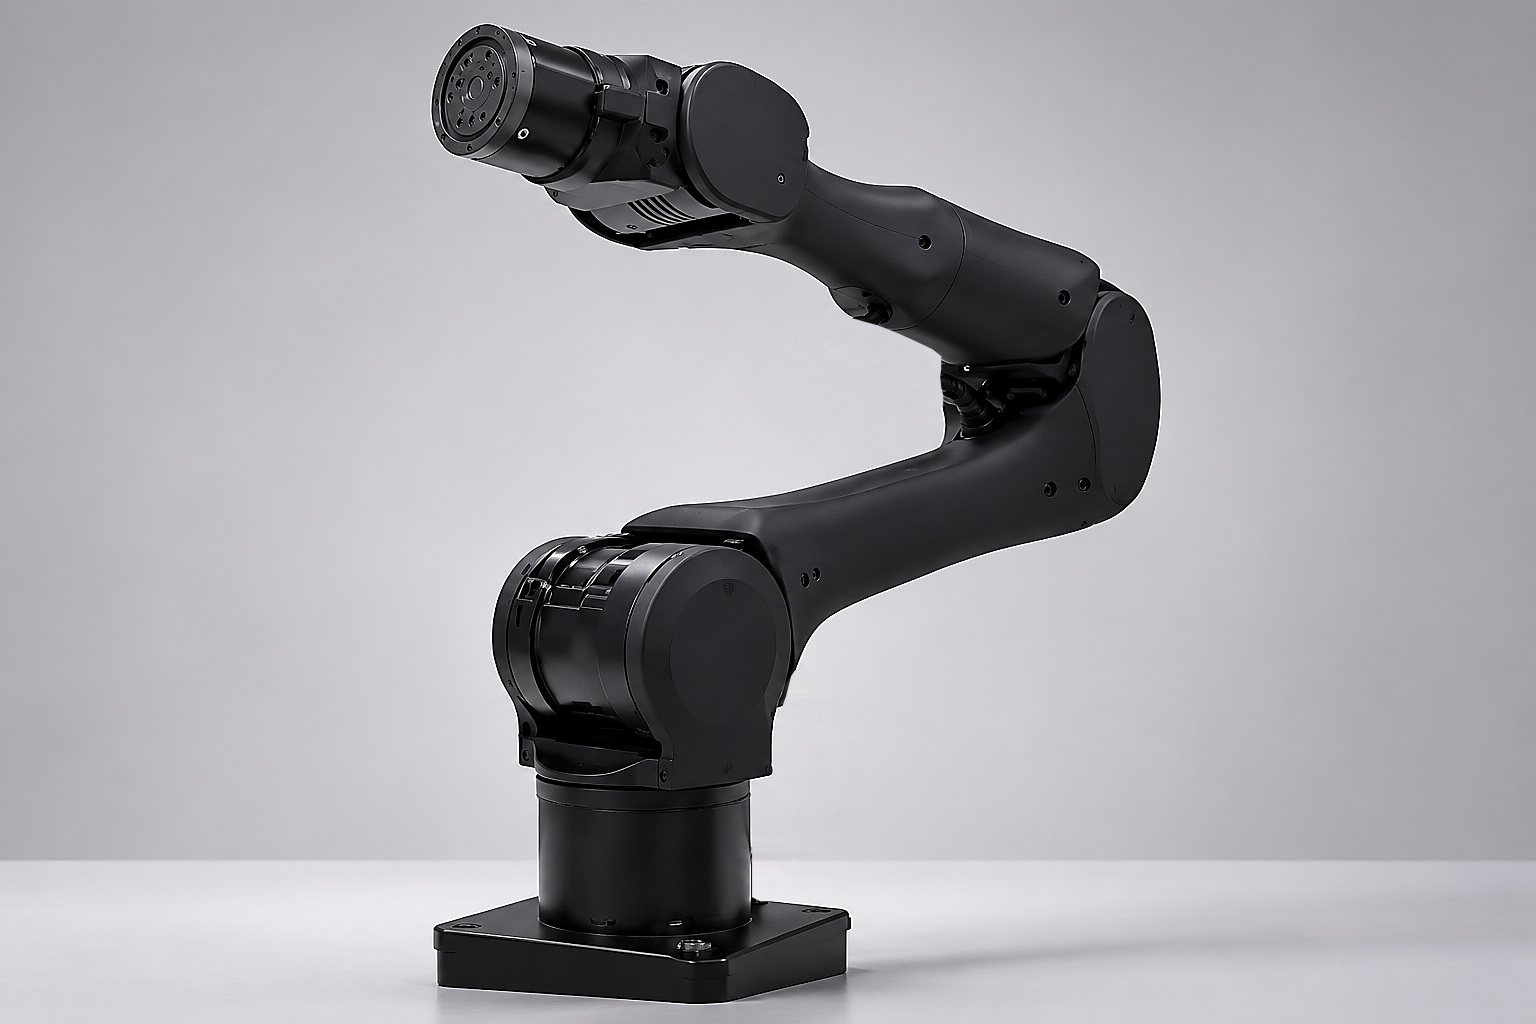
A six-axis desktop arm with a 2 kg payload. Built for teaching, manipulation and embodied AI development.
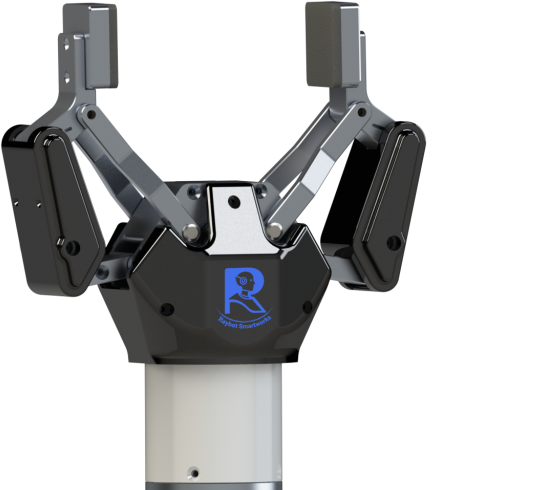
120 N rated gripping force. 105 mm total stroke. Adaptive two-finger gripping with CAN and EtherCAT.
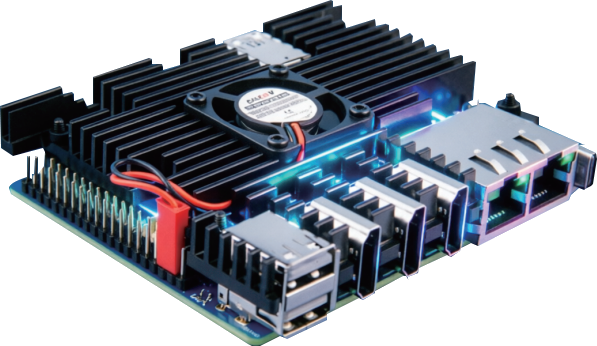
Dual 2.5 GbE. PREEMPT_RT. An integrated EtherCAT control platform for research, education and light automation.
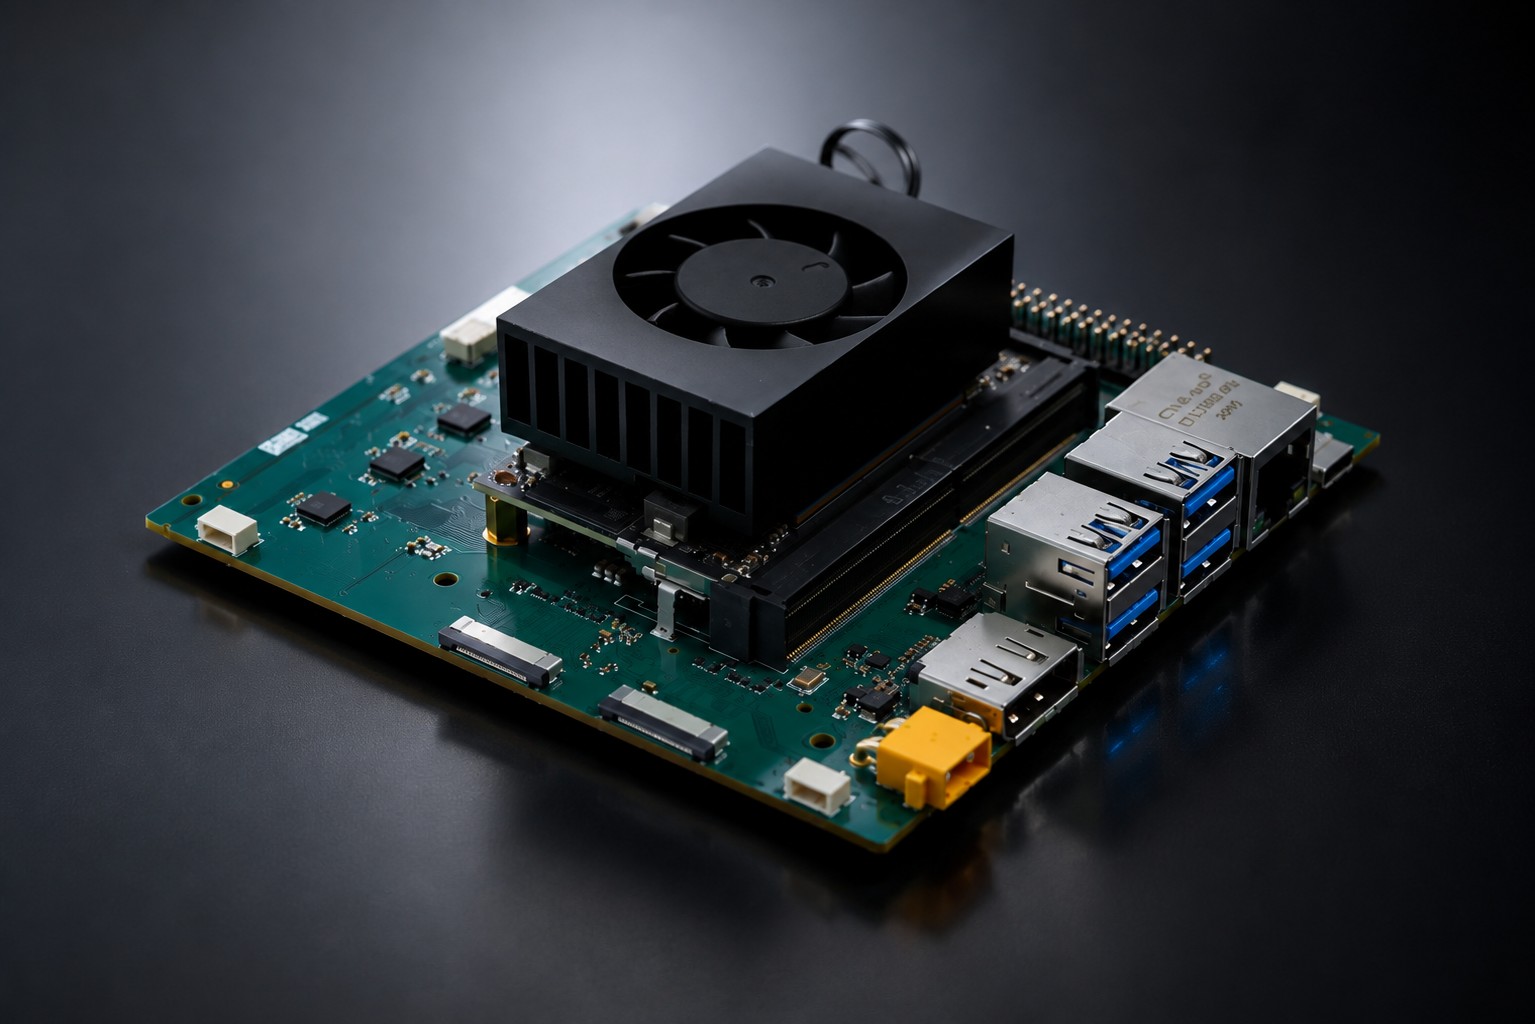
Jetson Orin NX SUPER 16GB. Up to 157 TOPS. Five independent EtherCAT ports for an integrated robot architecture.
Desktop robot arm
A six-axis desktop arm with a 2 kg payload. Built for teaching, manipulation and embodied AI development.
View productRobot arm
Seven axes. 850 mm reach. A 10 kg payload for embodied intelligence and precision automation.
View productReal-time controller
Dual 2.5 GbE. PREEMPT_RT. An integrated EtherCAT control platform for research, education and light automation.
View productEdge AI controller
Jetson Orin NX SUPER 16GB. Up to 157 TOPS. Five independent EtherCAT ports for an integrated robot architecture.
View productIntelligent gripper
90 N rated gripping force. 95 mm total stroke. Adaptive gripping in a compact 0.8 kg end effector.
View productAdaptive gripper
120 N rated gripping force. 105 mm total stroke. Adaptive two-finger gripping with CAN and EtherCAT.
View productWe connect precision mechanics, electronics and motion control into a hardware platform for research, education and embodied AI development.
Six disciplines. One connected robot system.
Precision mechanisms, bionic joints and rigid robot bodies.
Embedded electronics and heterogeneous compute for perception and control.
Servo control, trajectory tracking and coordinated multi-axis motion.
Actuator expertise, connected to joint modules and complete robots.
Firmware, control and applications working as one system.
Standard interfaces, application examples and integration documentation.
Pre-integrated mechanics, electronics and joints reduce the work between an idea and its first prototype.
SDKs and APIs leave room for your algorithms, your applications and your next experiment.
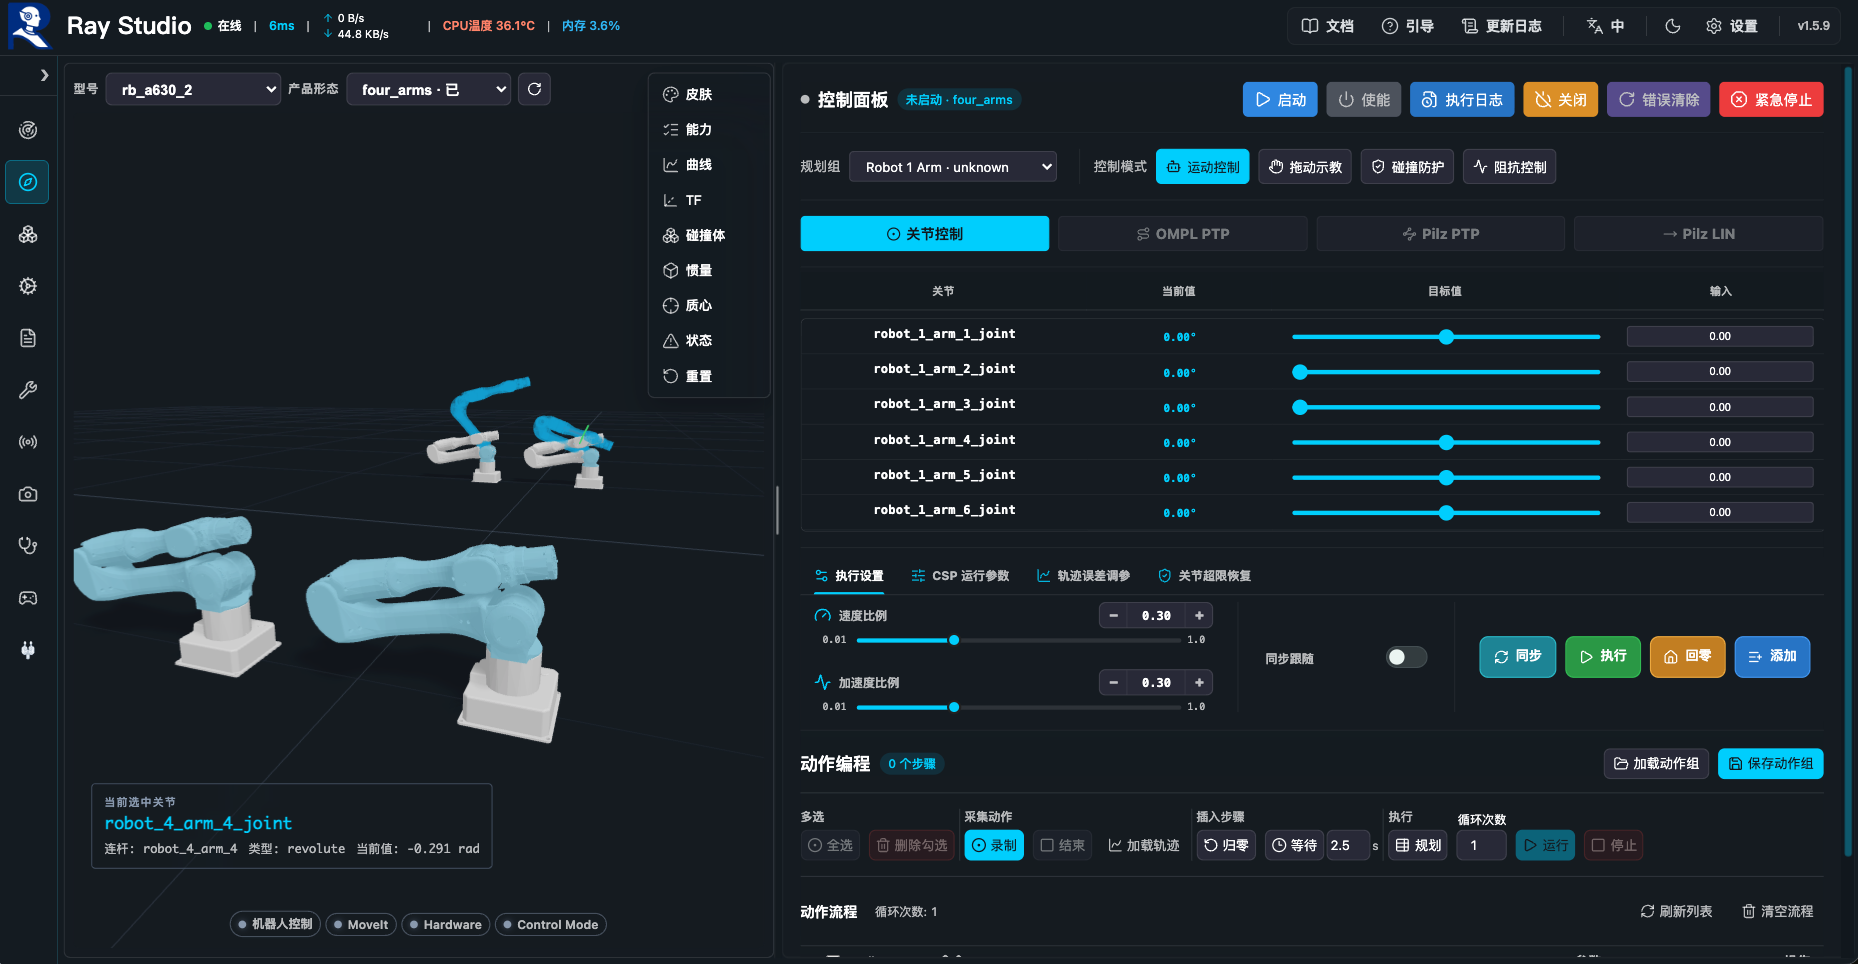
RayStudio connects control, teaching, tuning and visualization in one development workflow.
From a first prototype to a complete robot system, start a conversation with Raybot.
599 Yuanchuang Road, Huaqiao, Kunshan, Suzhou, Jiangsu, China.
Raybot hardware uses CAN and EtherCAT interfaces. Product documentation covers the supported interfaces and integration details. Raybot Studio provides a robot control and visualization environment.
Start with RB-A850-10 for a 7-axis robot arm. RB-C002 provides real-time robot control; RB-C004 adds Jetson Orin NX SUPER 16GB edge AI compute. Choose a GP2 gripper for the end effector.
Each product page includes its technical specifications. Download parameter sheets, outline drawings and operation manuals from the resource center.
The robot arm and grippers support CAN and EtherCAT communication. Contact our team to discuss the interfaces and configuration required for your application.
Contact Raybot sales with the model, quantity and your application. Our team will confirm the configuration, price and lead time for your project.
Email tangxc@myactuator.com or call +86 17775378663 for product selection, integration resources and technical support.